

Bu bölümün sesi bozuk olabilir.
How to fix it?
BU BÖLÜM HAKKINDA

In this episode, Audrow Nash interviews Dieter Fox, Professor in the Department of Computer Science and Engineering at the University of Washington, about the 100/100 Computer Vision Tracking Challenge. This is a self-imposed challenge to understand 100% of the pixels in an image 100% of the time in video footage; this includes understanding semantic information. Such understanding would allow robots to assist humans more naturally in environments like a home kitchen, wet lab, or in disaster response. To accomplish this challenge, Fox discusses challenges which include modeling, tracking, and detecting articulated objects.
ingilizce
Amerika Birleşik Devletleri
SON BÖLÜMLERİ ARA
Robohub Podcast için geçmiş bölümleri ara.
BU PODCAST'IN DİĞER BÖLÜMLERİ
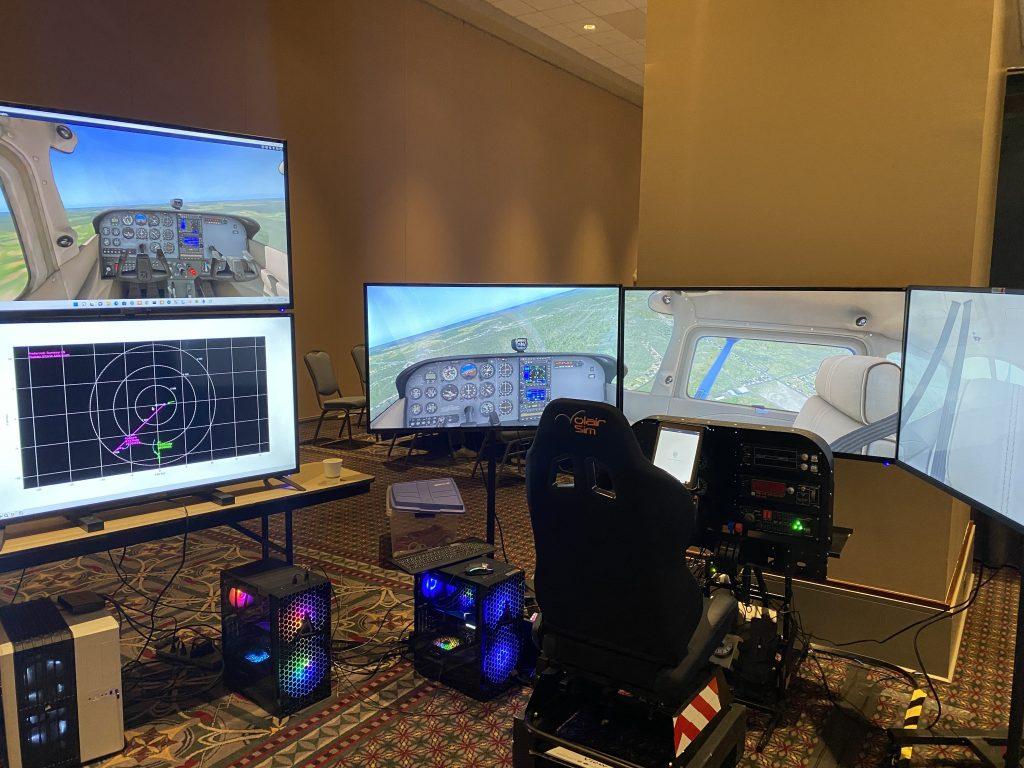
Sebastian Scherer from CMU's Airlab gives us a behind-the-scenes demo at ICRA of their Autonomous Flight Control AI. Their approach aims to cooperate with human pilots and act the way they would.
https://www.youtube.com/watch?v=ZPsJ4ArdtTk
The team took this approach to create a more natural, le…
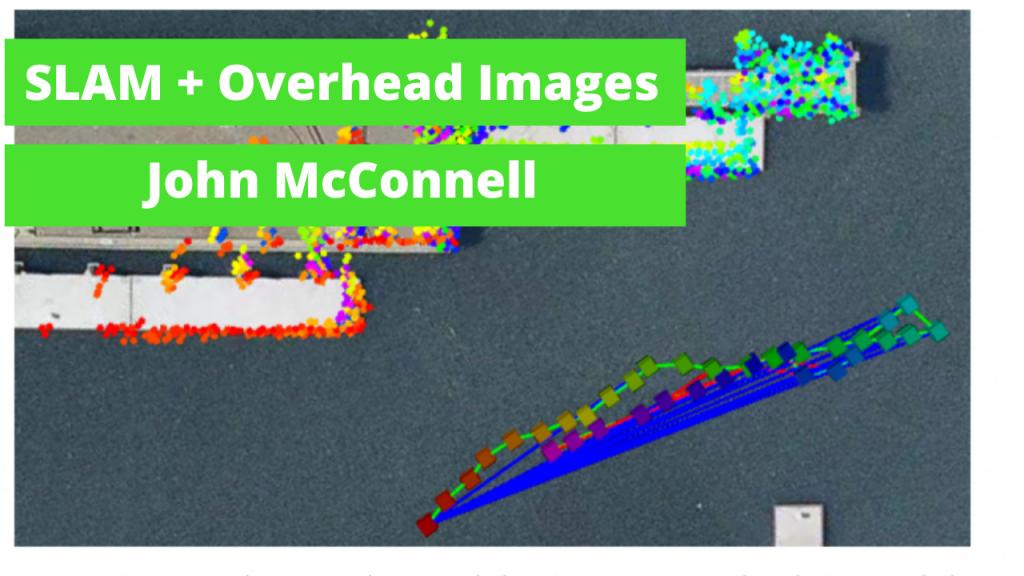
John McConnell discusses the research presented at ICRA 2022 to reduce drift in SLAM algorithms by incorporating overhead satellite imagery.
Brandon Gilles, the founder of Luxonis and maker of the OAK-D, describes the journey and the flexibility of the OAK-D line of products
Dr. Sihao Sun on his research for controlling a quadcopter after one of its rotors faces a sudden failure. His research takes in real-world assumptions where the quadcopter may already be in a compromised, difficult to correct orientation.
Brady Watkins gives insights into how a large company like Softbank Robotics approaches the Robotics market
Feragatname: Bu sayfaya yerleştirilmiş podcast ve sanat eserleri, sahibinin mülkiyetinde olan ve Listen Notes, Inc.'e bağlı olmayan veya tarafından onaylanmayan Robohub Podcast'e aittir.
DÜZENLE
Podcast veritabanını güncel tutmaya yardımcı olduğunuz için teşekkür ederiz.
