

이 에피소드의 오디오가 손상되었을 수 있습니다.
How to fix it?
이 에피소드에 관해

In this episode, Audrow Nash interviews Dieter Fox, Professor in the Department of Computer Science and Engineering at the University of Washington, about the 100/100 Computer Vision Tracking Challenge. This is a self-imposed challenge to understand 100% of the pixels in an image 100% of the time in video footage; this includes understanding semantic information. Such understanding would allow robots to assist humans more naturally in environments like a home kitchen, wet lab, or in disaster response. To accomplish this challenge, Fox discusses challenges which include modeling, tracking, and detecting articulated objects.
영어
미국
이 팟캐스트의 다른 에피소드
Dr. Sihao Sun on his research for controlling a quadcopter after one of its rotors faces a sudden failure. His research takes in real-world assumptions where the quadcopter may already be in a compromised, difficult to correct orientation.
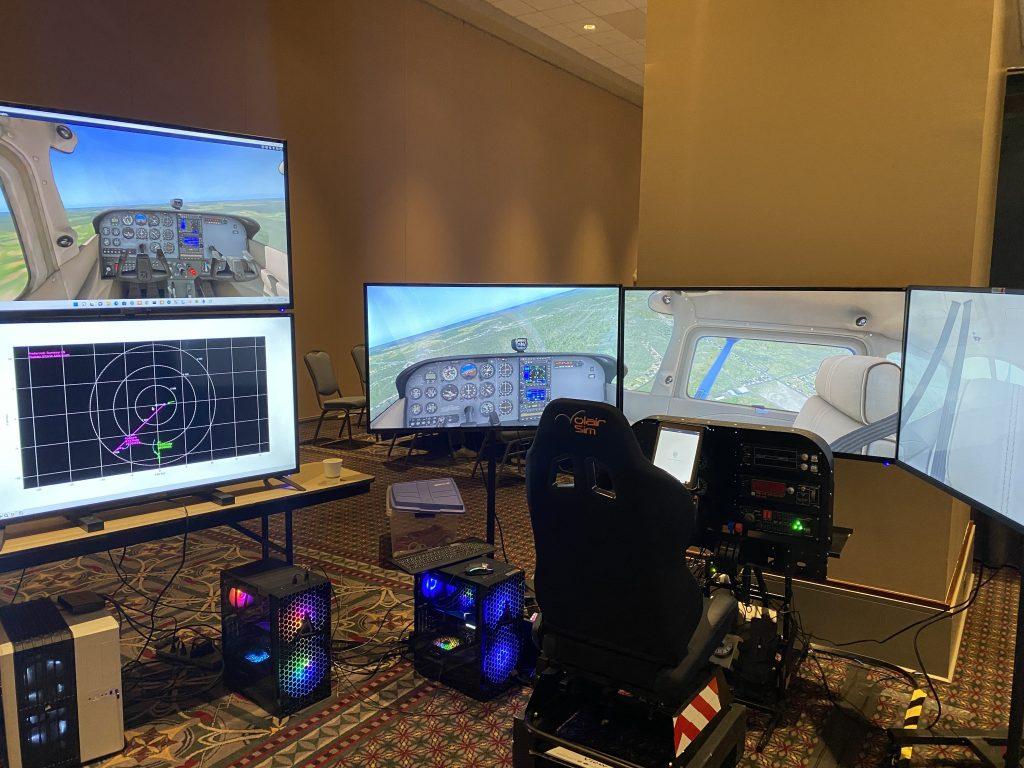
Sebastian Scherer from CMU's Airlab gives us a behind-the-scenes demo at ICRA of their Autonomous Flight Control AI. Their approach aims to cooperate with human pilots and act the way they would.
https://www.youtube.com/watch?v=ZPsJ4ArdtTk
The team took this approach to create a more natural, le…
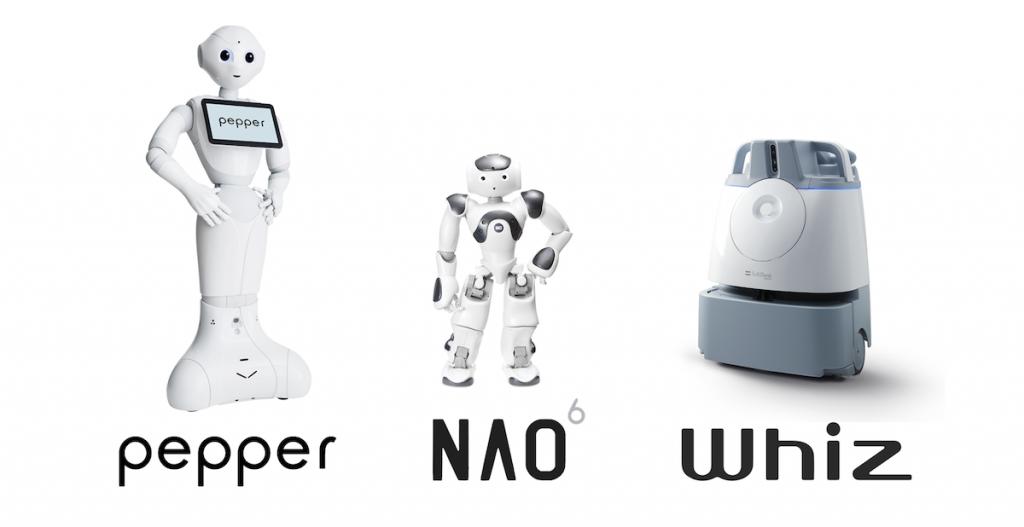
Brady Watkins gives insights into how a large company like Softbank Robotics approaches the Robotics market
Brandon Gilles, the founder of Luxonis and maker of the OAK-D, describes the journey and the flexibility of the OAK-D line of products
John McConnell discusses the research presented at ICRA 2022 to reduce drift in SLAM algorithms by incorporating overhead satellite imagery.
면책 조항: 이 페이지에 포함된 팟캐스트와 작품은 Robohub Podcast에서 가져온 것입니다. 이 팟캐스트는 소유자의 재산이며 Listen Notes, Inc.와 제휴하거나 보증하지 않습니다.
