

Lydfilen for denne episode er muligvis beskadiget
How to fix it?
OM DENNE EPISODE

In this episode, Audrow Nash interviews Dieter Fox, Professor in the Department of Computer Science and Engineering at the University of Washington, about the 100/100 Computer Vision Tracking Challenge. This is a self-imposed challenge to understand 100% of the pixels in an image 100% of the time in video footage; this includes understanding semantic information. Such understanding would allow robots to assist humans more naturally in environments like a home kitchen, wet lab, or in disaster response. To accomplish this challenge, Fox discusses challenges which include modeling, tracking, and detecting articulated objects.
Engelsk
USA
SØG BLANDT TIDLIGERE EPISODER
Søg efter gamle afsnit af Robohub Podcast.
ANDRE EPISODE I DENNE PODCAST
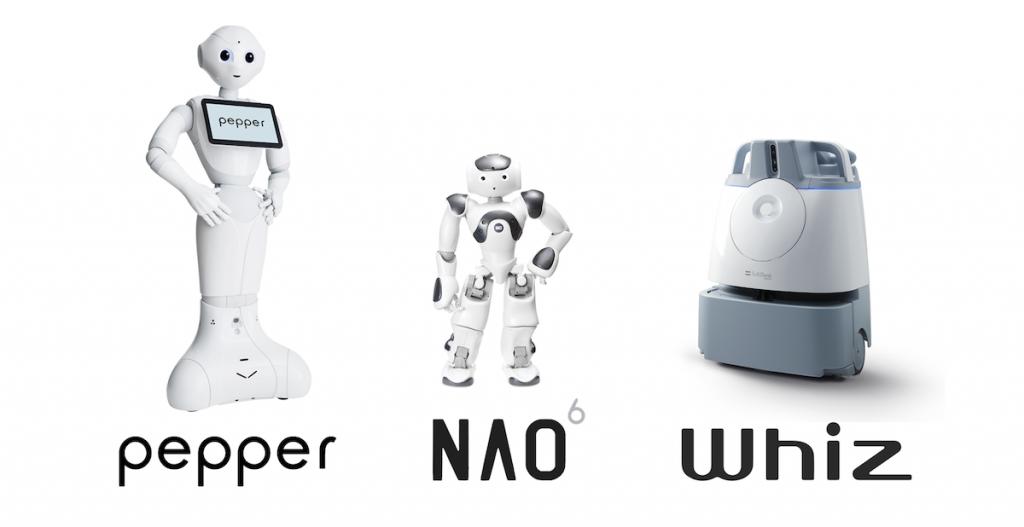
Brady Watkins gives insights into how a large company like Softbank Robotics approaches the Robotics market
Dr. Sihao Sun on his research for controlling a quadcopter after one of its rotors faces a sudden failure. His research takes in real-world assumptions where the quadcopter may already be in a compromised, difficult to correct orientation.
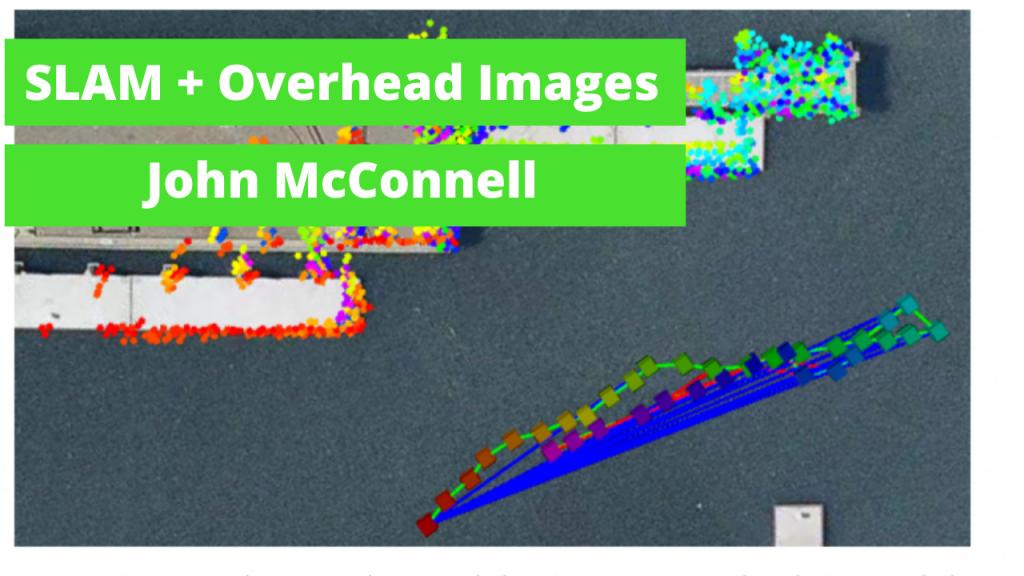
John McConnell discusses the research presented at ICRA 2022 to reduce drift in SLAM algorithms by incorporating overhead satellite imagery.
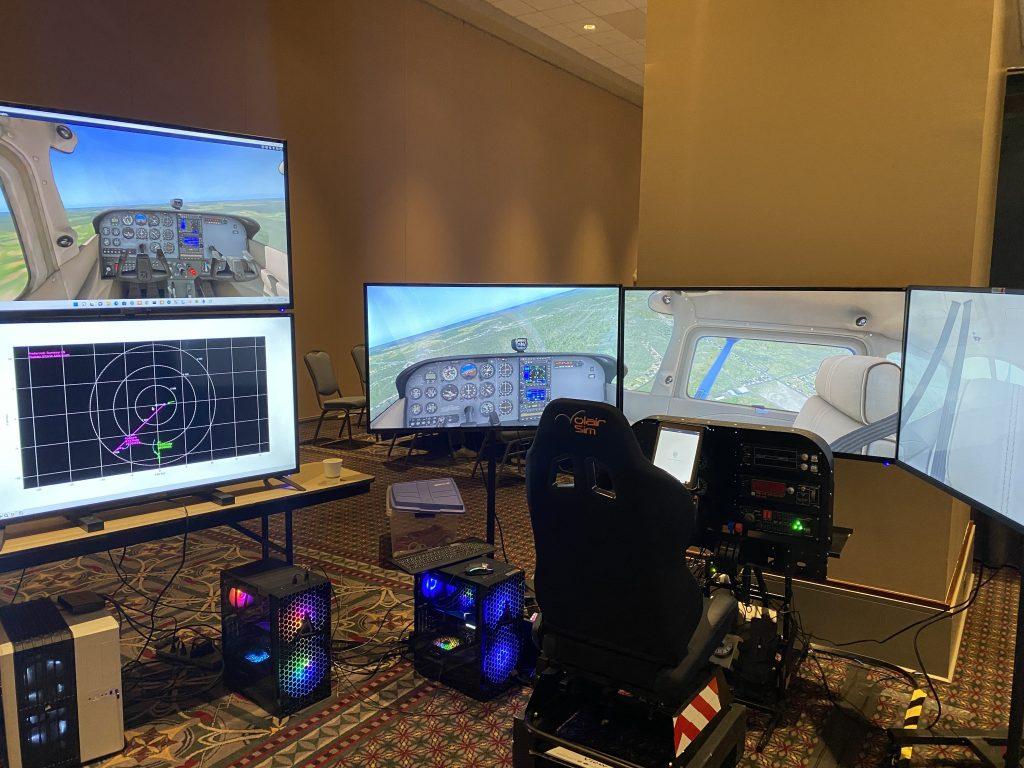
Sebastian Scherer from CMU's Airlab gives us a behind-the-scenes demo at ICRA of their Autonomous Flight Control AI. Their approach aims to cooperate with human pilots and act the way they would.
https://www.youtube.com/watch?v=ZPsJ4ArdtTk
The team took this approach to create a more natural, le…
Brandon Gilles, the founder of Luxonis and maker of the OAK-D, describes the journey and the flexibility of the OAK-D line of products
Ansvarsfraskrivelse: Podcasten og kunstværket, der er indlejret på denne side, er fra Robohub Podcast, som tilhører dens ejer og ikke er tilknyttet eller godkendt af Listen Notes, Inc.
REDIG
Tak fordi du hjælper med at holde podcast-databasen opdateret.
